IN Brief:
- VIAVI's Inertial Labs business has launched INS-NV, combining tactical-grade MEMS navigation sensors with NVIDIA Jetson Orin NX processing.
- The platform supports visual navigation and additional sensor inputs for positioning applications where GNSS signals are unreliable.
- INS-NV is available now, with MAVLink, ASPN, pntOS and MOSA-compatible configurations offered on request.
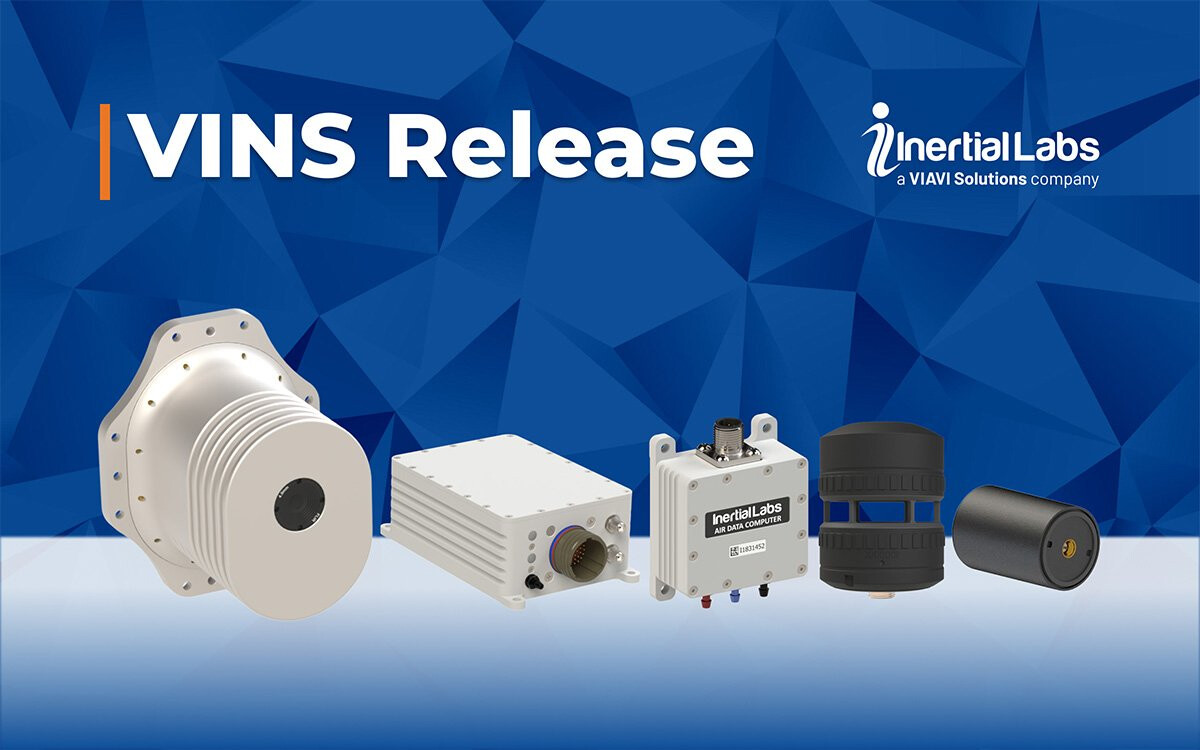
VIAVI Solutions has launched a programmable inertial navigation development platform through its Inertial Labs business, combining tactical-grade MEMS sensing, satellite navigation and an NVIDIA Jetson Orin NX processor. The INS-NV is intended for developers working on positioning, navigation and timing systems that must maintain useful operation when satellite signals are obstructed, disrupted or deliberately manipulated.
The platform integrates an inertial navigation system, an attitude and heading reference system and a multi-constellation GNSS receiver with onboard computing. Bringing these functions into a common development platform allows navigation algorithms and supporting applications to run close to the sensors, reducing the separate hardware integration required before a development team can begin testing its approach.
Inertial navigation relies on measurements from accelerometers and gyroscopes to estimate how a vehicle moves and changes orientation. The sensors do not depend on an external radio reference for each measurement, allowing navigation estimates to continue during a loss of GNSS reception. Their errors accumulate over time, however, so a position calculated solely by integrating inertial measurements will generally drift away from the true location.
External aiding measurements help constrain that drift. GNSS normally provides position information, while cameras, radio ranging systems, maps and other references can contribute information when satellite reception is unreliable. Combining measurements from different sources requires software that understands their timing, uncertainty and possible failure modes. A sensor fusion system must avoid treating a corrupted reference as an accurate correction to an otherwise valid navigation estimate.
INS-NV incorporates the NVIDIA Jetson Orin NX module to support computationally demanding navigation applications, including visual odometry and image processing. A camera can estimate movement by tracking features through successive images, while software compares that information with the movement calculated from inertial sensors. The results depend on conditions such as lighting, camera calibration, visible scene features and the interval between measurements.
VIAVI also identifies alternative positioning and timing functions supported by the wider Inertial Labs aiding ecosystem. The published technical documentation includes examples using visual inertial odometry, visual positioning, radio-frequency ranging and Iridium positioning and timing assistance. These methods offer different ways to provide a reference when GNSS reception deteriorates, but they do not share a single accuracy figure applicable under all conditions.
The manufacturer’s performance table distinguishes between configurations according to the aiding data available. Its GNSS-denied figures are tied to particular methods, including visual navigation and external radio references. The published estimates should therefore be read in conjunction with the specified test conditions rather than used as evidence that a standalone INS-NV maintains the same position accuracy indefinitely without GNSS.
Processing capacity is another factor in navigation system development. Running visual algorithms on an embedded processor can reduce dependence on a separate computing unit, but the overall implementation must still accommodate camera bandwidth, memory consumption, latency and power requirements. A more demanding perception algorithm may provide additional environmental information while consuming resources needed by other vehicle functions.
The INS-NV datasheet identifies serial interfaces, Ethernet, USB and general-purpose input and output connections, alongside timing and camera control signals. The development platform can consequently communicate with external sensors and host controllers, although the application must implement the required data handling and control logic. Interface availability alone does not establish interoperability with every commercial camera, autopilot or robotics controller.
The enclosed system is specified at approximately 480g, with a 9V to 36V DC power input and nominal power consumption of 15W. An OEM configuration is also described. These requirements are relevant to vehicle integration, particularly for smaller unmanned platforms where the navigation unit competes with communications equipment, sensors and payload systems for available power and installation space.
VIAVI offers versions compatible with MAVLink, Assured Positioning, Navigation and Timing Service protocols, pntOS and Modular Open Systems Approach requirements on request. Those options support integration with different control and communications architectures, but developers must still establish compatibility with the precise implementations and software versions in their equipment.
The company identifies autonomous vehicles, unmanned systems and advanced navigation research among the intended applications. A common inertial and computing platform can provide a practical environment for comparing algorithms and external aiding arrangements before a more specialised system is designed. The outcome of those evaluations will depend on the reliability of the selected sensors and the software’s behaviour when reference measurements become inconsistent.
INS-NV is available now. The launch establishes a configurable development product rather than an independently demonstrated navigation capability suitable for every GNSS-denied environment. Final performance must be established for the particular combination of sensors, algorithms and operating conditions chosen by the system developer.