IN Brief:
- Microchip's ATFCD52 supports arrays configured with up to 32 transmit and 20 receive lines.
- Twenty parallel analogue front ends provide frame acquisition up to 800Hz, depending on array dimensions, with sensitivity below 1fF.
- The EV-ATFCD52 evaluation kit supports a supplied 10 × 10 sensor, custom arrays, and real-time data visualisation.
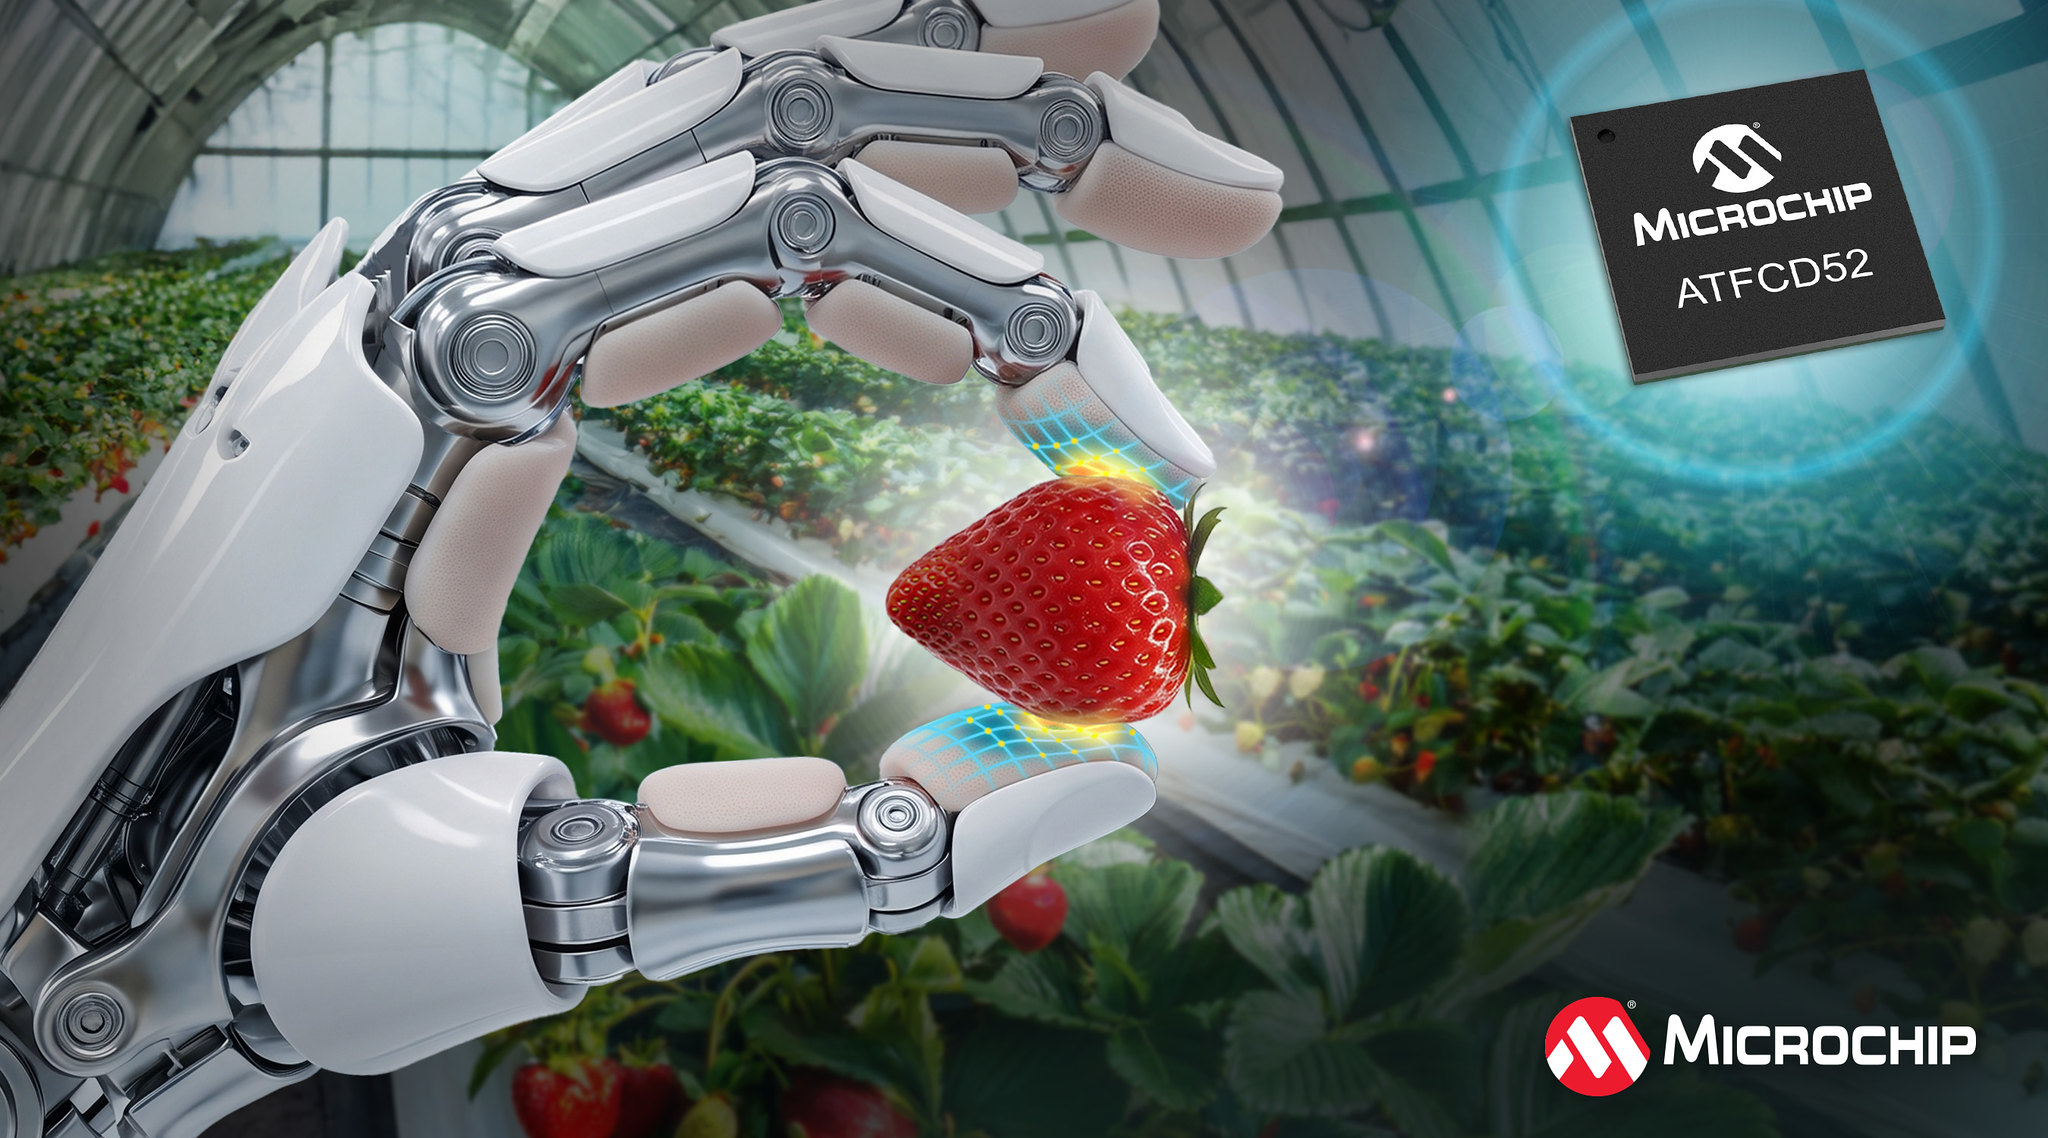
Microchip Technology has introduced the ATFCD52, a high-speed capacitance digitiser designed to collect tactile measurements from two-dimensional sensor arrays used in robotic grippers and other contact-sensitive equipment. The device supports up to 32 transmit and 20 receive lines, with frame acquisition rates reaching 800Hz for suitable sensor configurations.
The ATFCD52 converts small changes in capacitance into digital information that an external microcontroller, microprocessor, or FPGA can interpret. These measurements can support calculations of contact forces and changes in grip conditions, allowing a robotic control system to respond when an object begins moving within a gripper.
Machine vision provides information about an object's visible position and geometry, but the forces acting at the contact surface require a different measurement method. Capacitive tactile sensors can detect deformation of a sensing structure, producing electrical changes associated with pressure and movement. Combining this information with a robot's existing control system provides a means of monitoring physical contact during manipulation.
The ATFCD52 is intended for fine-grid, two-dimensional capacitive arrays. Its architecture supports up to 32 transmit lines and 20 receive lines, rather than providing 52 independent force-measurement channels. Sensor intersections within the connected array can be evaluated to produce a spatial representation of changes in capacitance across the contact surface.
Twenty parallel analogue front ends allow the device to acquire information from the receive lines simultaneously. This reduces the amount of sequential acquisition needed compared with architectures that rely on a smaller number of measurement circuits. The achievable frame rate still depends on the array configuration and the settings selected for the particular application.
Microchip specifies acquisition rates of up to 800Hz. At that rate, the interval between successive completed frames is approximately 1.25 milliseconds, but this does not represent the complete response time of a robotic gripper. Subsequent processing, communications, actuator control, and mechanical movement contribute additional delays.
High acquisition rates can nevertheless help a controller identify changes in contact conditions before an object has moved significantly. Slip detection is a particular application: a robot handling a fragile object needs enough force to maintain its grip without applying excessive pressure. Tactile measurements can inform adjustments to that force as contact conditions change.
The device is designed to resolve capacitance changes below one femtofarad. Such small electrical variations can arise when a compliant sensor surface deforms under light pressure. The relationship between measured capacitance and applied force is not fixed by the digitiser alone, however, because sensor materials, electrode geometry, mechanical construction, and calibration influence the result.
Calculating normal and shear forces requires additional processing. Normal force acts perpendicular to the contact surface, while shear force acts along it. A useful tactile control system may need to distinguish between these components to determine whether an object is being pressed securely or beginning to slide.
Sensor calibration is therefore an important part of development. A particular array may respond differently to the same applied force at different locations, while temperature, material ageing, and repeated deformation can influence its behaviour. An application that relies on quantitative force estimation must establish how the electrical measurements correspond to the actual mechanical conditions.
Electromagnetic interference also presents a challenge. Robotic equipment commonly incorporates motors, switching regulators, power converters, and communication electronics that can generate electrical disturbances. Those signals may couple into sensor conductors and obscure the small capacitance variations that the digitiser is intended to measure.
Microchip has incorporated frequency hopping and oversampling to help reduce the influence of interference. Frequency hopping allows acquisition conditions to be changed when particular frequencies are affected, while oversampling can improve the extraction of useful measurements from noisy data. Their effectiveness depends on the interference environment and the configuration of the connected sensor.
The ATFCD52 is not a complete robotic grip controller. Its digital output must be interpreted by a separate processing device, which may combine tactile information with other measurements and generate commands for the actuators. Microchip identifies its microcontrollers, microprocessors, and FPGAs as potential processing platforms, allowing the architecture to be selected according to the required computational resources.
Development support includes the EV-ATFCD52 evaluation kit and ATFCD52 Configurator software. The kit contains a 10 × 10 capacitive sensor arrangement with sample material for constructing a tactile surface, while an 80-way flexible-cable connector allows a custom sensor array to be attached.
The evaluation hardware supports full-frame capture and real-time graphical visualisation of sensor data. Configuration and tuning are carried out using the ATFCD52 software plug-in for maXTouch Studio, enabling developers to examine the response of different sensing materials and operating settings.
Communication with the evaluation hardware requires Microchip's USB High Speed Bridge Board V2, part number EV51X39A, which is sold separately. The bridge provides I²C configuration and SPI frame-data capture, distinguishing the development interface from the high-speed sensing circuitry itself.
Microchip identifies instrumented gloves, pressure-sensitive mats, wearable sensing, and electronic skin among the possible applications. These systems have different mechanical requirements, but can use related methods of capacitive measurement and digital acquisition.
The ATFCD52 is available through Microchip and its distribution network. The manufacturer has not published comparative results demonstrating a specific improvement in robotic grip accuracy or slip prevention across different sensor designs. Those outcomes will depend on the complete sensor construction, processing algorithms, and control-system response.